Computer Networks · TEE · papers
Q1(c) · CSMA persistence
2024-02-06 · 2022-23
Actual paper; 100 marks attempted. Current-syllabus alignment is stated per question.
Q1(c). Compare and contrast 1 persistent and p persistent schemes in multiple access with flow diagrams. [5 marks]
Answer
Definition. Persistence specifies how a station behaves after observing that the medium is busy or becomes idle.
Simple meaning. 1 = turant; non = random wait; p = probability ke basis pe start.
Understand it step by step
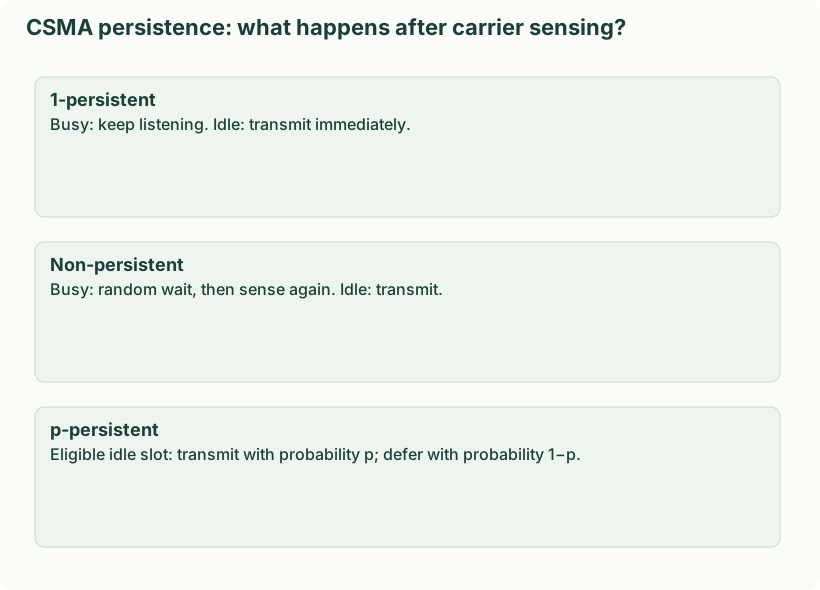
- In 1-persistent CSMA, a ready station transmits immediately when idle; when busy it continuously senses. Several waiting stations may all start at the same idle transition.
- In non-persistent CSMA, a busy observation causes a random wait before the next sensing attempt. This reduces simultaneous retries but can waste some idle time.
- In p-persistent CSMA, when an eligible idle slot begins, transmit with probability p. With probability 1−p, defer to a later slot and sense again. The probabilistic decision is repeated, not a one-time discard.
| Rule | When idle | When busy | Trade-off |
|---|---|---|---|
| 1-persistent | Transmit immediately | Keep listening; transmit as soon as idle | Low idle delay, but waiting stations may start together |
| Non-persistent | Transmit | Wait a random time, then sense again | Less synchronized contention; may leave avoidable idle time |
| p-persistent (slotted) | Transmit with probability p; defer a slot with probability 1−p | Wait until available, then resume the probabilistic slot rule | Controls contention; needs slots and a choice of p |
Yaad rakho: 1 = start now; non = wait then listen; p = chance per idle slot.
Definition. CSMA with Collision Detection monitors the medium during transmission, aborts a detected collision and retries after a randomized backoff.
Simple meaning. CD = takkar detect hui toh transmission rok do.
Understand it step by step
- Sense the channel. In traditional shared half-duplex Ethernet, begin transmission when permitted by the access rule.
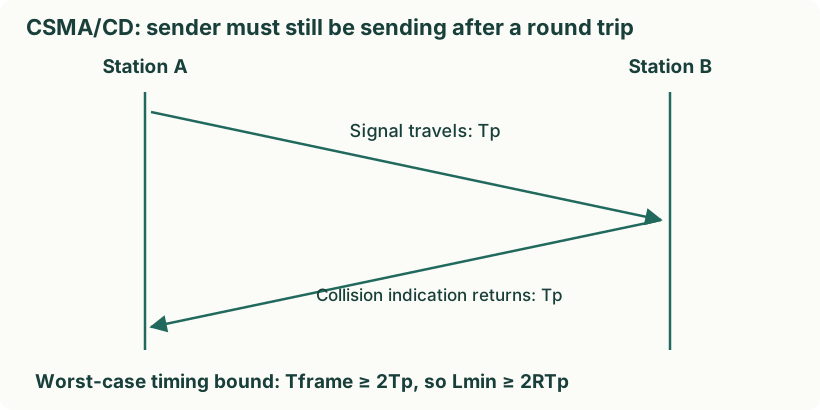
- Continue monitoring while transmitting. If a collision is detected, send the collision/jam indication and abort the current frame.
- Choose a random delay using binary exponential backoff; then attempt again subject to the access rules.
- The sender must still be transmitting when a worst-case collision indication returns. Hence the ideal timing requirement is Tframe ≥ 2Tp.
- Modern switched full-duplex Ethernet links do not use collision-based CSMA/CD access. Keep the historical/shared-medium assumptions explicit.
 LaTeX:
T_{\mathrm{frame}}\geq 2T_p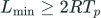 LaTeX:
L_{\min}\geq 2RT_pCSMA/CD senses before transmission and detects collisions during transmission. A collision causes abort/jam and a random backoff before retry. To detect the most distant collision before the frame finishes, the transmission duration must be at least the worst-case round-trip propagation delay. Thus Lmin/R ≥ 2Tp in the idealized model.
Yaad rakho: Detect karna hai toh sender tab tak bhej raha hona chahiye.
Persistence decision flows
1-persistent:
Ready → sense → busy? yes → sense again
                      no → transmit immediately

p-persistent (slotted medium):
Ready → sense → busy? yes → wait and sense
                      no → draw random decision
                    probability p → transmit
                  probability 1−p → wait one slot → sense again
Non-persistent CSMA instead waits a random time after a busy observation before sensing again. A collision leads to the protocol's retry/backoff procedure; the persistence rule alone does not guarantee success.