Intelligent Systems II · M2 · mocks
Q3 · Two-particle PSO through iteration 2 [3]
M2 mock 3 · 10 marks
Q1(a)+Q1(b) compulsory; any two of Q2–Q4. Answers immediately below each question.
Confirmed M2 pattern: Q1(a) [2] and Q1(b) [2] are compulsory. Attempt any two of Q2, Q3 and Q4, each worth 3 marks. The paper offers 13 marks; you attempt 10. These are newly written practice questions, not claims about the exact upcoming paper. Solutions are directly below each question; the teaching working is deliberately longer than a concise exam answer.
Q3. Minimise  LaTeX:
f(x)=x^2 using 2 particles. Use the initial data below and perform exactly two PSO iterations, reporting position, velocity, pbest and gbest after each iteration. [3 marks · Practice; expanded teaching solution]
Given
| Particle | Initial position x⁰ | Initial velocity v⁰ |
|---|---|---|
| A | (1) | (2) |
| B | (4) | (-1) |
w=0.5, c₁=1, c₂=1, r₁=0.5, r₂=0.5. Initialise each pbest at its initial position. Use these random coefficients unchanged in both iterations. No bounds or velocity clamp are imposed in this example. Updates are synchronous: every particle uses the same previous-iteration gbest.
To find
The complete swarm state after iterations 1 and 2, and the best location found.
Formula and why it applies
PSO combines inertia, personal memory and shared memory. Subtract positions coordinate by coordinate. Evaluate the objective only after moving. For minimisation, replace a best only when its score decreases.
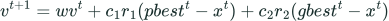 LaTeX:
v^{t+1}=wv^t+c_1r_1(pbest^t-x^t)+c_2r_2(gbest^t-x^t)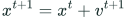 LaTeX:
x^{t+1}=x^t+v^{t+1}Solution
Step 1. Evaluate every initial position
Particle A
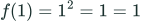 LaTeX:
f(1)=1^2=1=1Particle B
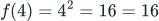 LaTeX:
f(4)=4^2=16=16Step 2. Initialise the memories
pbest is each initial position because there is no earlier history. The smallest objective decides gbest.
 LaTeX:
gbest^0=(1)Its score is 1. Store the position, not only the score.
Step 3. Iteration 1: freeze the previous memories
All particles in this iteration use gbest = (1). pbest values are A: (1), B: (4).
Step 4. Iteration 1: update particle A
Only coordinate
Inertia = keep a fraction of the old velocity.
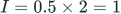 LaTeX:
I=0.5\times2=1Personal pull: first subtract the current coordinate from the personal-best coordinate.
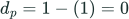 LaTeX:
d_p=1-(1)=0Multiply the two personal coefficients, then multiply by the difference.
 LaTeX:
c_1r_1=1\times0.5=0.5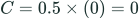 LaTeX:
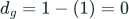
C=0.5\times(0)=0Social pull: subtract the current coordinate from the frozen global-best coordinate.
 LaTeX:
d_g=1-(1)=0Multiply the social coefficients, then multiply by that difference.
 LaTeX:
c_2r_2=1\times0.5=0.5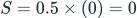 LaTeX:
S=0.5\times(0)=0Add the three velocity contributions.
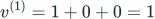 LaTeX:
v^{(1)}=1+0+0=1Add the new velocity to the old position. The parenthesised upper label is the iteration number.
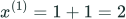 LaTeX:
x^{(1)}=1+1=2Step 5. Iteration 1: update particle B
Only coordinate
Inertia = keep a fraction of the old velocity.
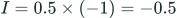 LaTeX:
I=0.5\times(-1)=-0.5Personal pull: first subtract the current coordinate from the personal-best coordinate.
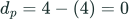 LaTeX:
d_p=4-(4)=0Multiply the two personal coefficients, then multiply by the difference.
LaTeX: c_1r_1=1\times0.5=0.5LaTeX: C=0.5\times(0)=0Social pull: subtract the current coordinate from the frozen global-best coordinate.
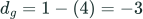 LaTeX:
d_g=1-(4)=-3Multiply the social coefficients, then multiply by that difference.
LaTeX: c_2r_2=1\times0.5=0.5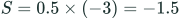 LaTeX:
S=0.5\times(-3)=-1.5Add the three velocity contributions.
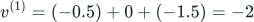 LaTeX:
v^{(1)}=(-0.5)+0+(-1.5)=-2Add the new velocity to the old position. The parenthesised upper label is the iteration number.
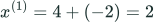 LaTeX:
x^{(1)}=4+(-2)=2Step 6. Iteration 1: evaluate the new positions
Particle A
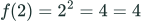 LaTeX:
f(2)=2^2=4=4Particle B
LaTeX: f(2)=2^2=4=4Step 7. Iteration 1: update pbest, then gbest
| Particle | Old pbest score | New score | Decision | pbest position |
|---|---|---|---|---|
| A | 1 | 4 | Keep old: new score is worse | (1) |
| B | 16 | 4 | Replace: new score is lower | (2) |
Compare the retained pbest scores. gbest = (1), with objective 1.
Step 8. Iteration 1: record the complete state
| Particle | Position | Velocity | pbest |
|---|---|---|---|
| A | (2) | (1) | (1) |
| B | (2) | (-2) | (2) |
Step 9. Iteration 2: freeze the previous memories
All particles in this iteration use gbest = (1). pbest values are A: (1), B: (2).
Step 10. Iteration 2: update particle A
Only coordinate
Inertia = keep a fraction of the old velocity.
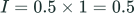 LaTeX:
I=0.5\times1=0.5Personal pull: first subtract the current coordinate from the personal-best coordinate.
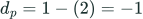 LaTeX:
d_p=1-(2)=-1Multiply the two personal coefficients, then multiply by the difference.
LaTeX: c_1r_1=1\times0.5=0.5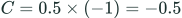 LaTeX:
C=0.5\times(-1)=-0.5Social pull: subtract the current coordinate from the frozen global-best coordinate.
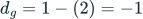 LaTeX:
d_g=1-(2)=-1Multiply the social coefficients, then multiply by that difference.
LaTeX: c_2r_2=1\times0.5=0.5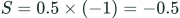 LaTeX:
S=0.5\times(-1)=-0.5Add the three velocity contributions.
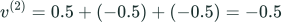 LaTeX:
v^{(2)}=0.5+(-0.5)+(-0.5)=-0.5Add the new velocity to the old position. The parenthesised upper label is the iteration number.
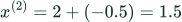 LaTeX:
x^{(2)}=2+(-0.5)=1.5Step 11. Iteration 2: update particle B
Only coordinate
Inertia = keep a fraction of the old velocity.
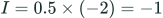 LaTeX:
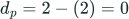
I=0.5\times(-2)=-1Personal pull: first subtract the current coordinate from the personal-best coordinate.
 LaTeX:
d_p=2-(2)=0Multiply the two personal coefficients, then multiply by the difference.
LaTeX: c_1r_1=1\times0.5=0.5LaTeX: C=0.5\times(0)=0Social pull: subtract the current coordinate from the frozen global-best coordinate.
LaTeX: d_g=1-(2)=-1Multiply the social coefficients, then multiply by that difference.
LaTeX: c_2r_2=1\times0.5=0.5LaTeX: S=0.5\times(-1)=-0.5Add the three velocity contributions.
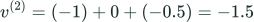 LaTeX:
v^{(2)}=(-1)+0+(-0.5)=-1.5Add the new velocity to the old position. The parenthesised upper label is the iteration number.
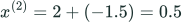 LaTeX:
x^{(2)}=2+(-1.5)=0.5Step 12. Iteration 2: evaluate the new positions
Particle A
 LaTeX:
f(1.5)=1.5^2=2.25=2.25Particle B
 LaTeX:
f(0.5)=0.5^2=0.25=0.25Step 13. Iteration 2: update pbest, then gbest
| Particle | Old pbest score | New score | Decision | pbest position |
|---|---|---|---|---|
| A | 1 | 2.25 | Keep old: new score is worse | (1) |
| B | 4 | 0.25 | Replace: new score is lower | (0.5) |
Compare the retained pbest scores. gbest = (0.5), with objective 0.25.
Step 14. Iteration 2: record the complete state
| Particle | Position | Velocity | pbest |
|---|---|---|---|
| A | (1.5) | (-0.5) | (1) |
| B | (0.5) | (-1.5) | (0.5) |